OpenNeoData
Description
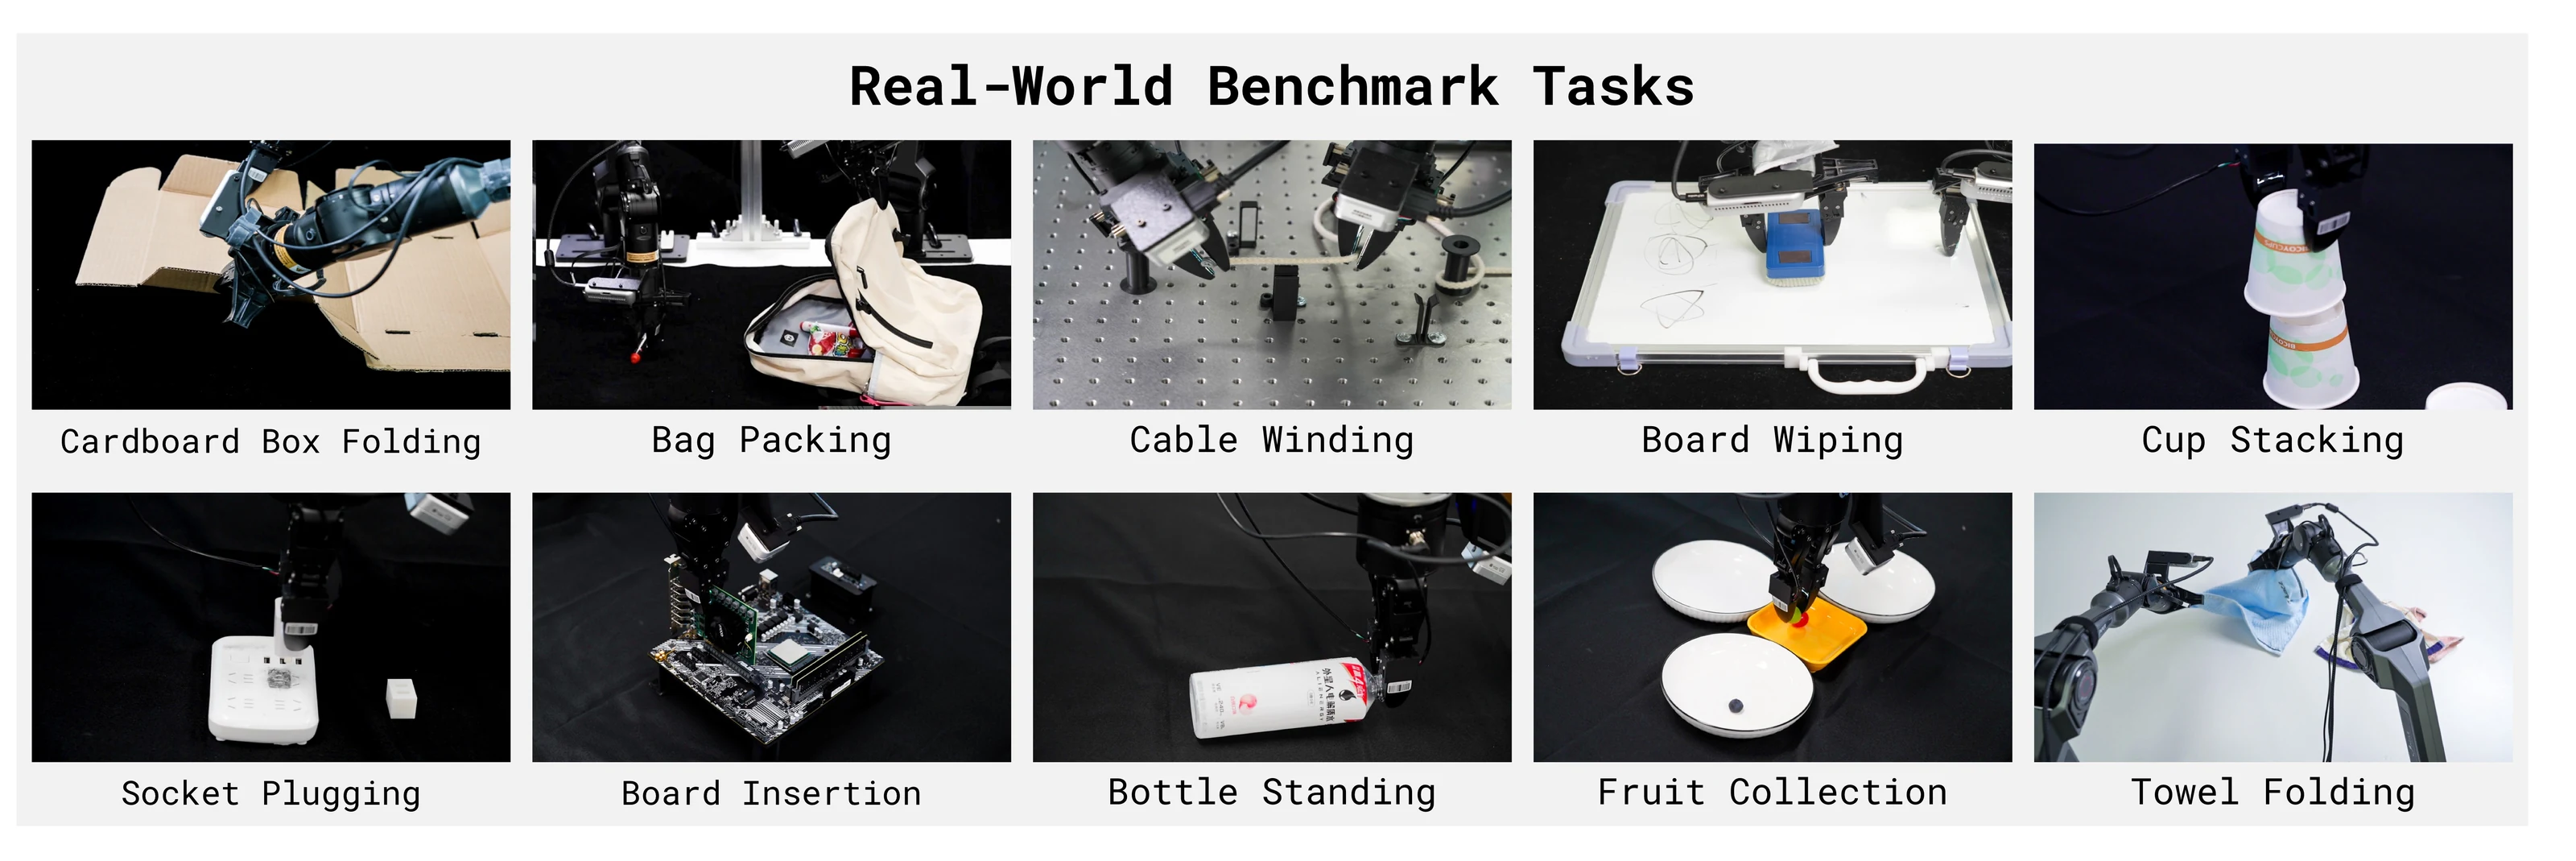
OpenNeoData is the public visuotactile manipulation subset of NeoteAI’s larger NeoData corpus. The publisher reports more than 5,000 hours, 200,000 trajectories, and 257 task types across six embodiments, including fixed robot arms and handheld UMI collection devices. The LeRobot v3.0 release synchronizes external and wrist RGB, gel-sensor tactile video, state, and actions, with embodiment-specific end-effector representations. It covers contact-rich manipulation, deformable objects, precise placement, and bimanual coordination. Downloads are organized by embodiment and require accepting the publisher’s contact-information gate.
License
CC BY-NC-SA 4.0 for all data and code in the dataset repository; non-commercial use only.*
* Double-check the publisher's current license and usage terms before using this dataset.