humanoidsdata.com

Search

Search companies, datasets, articles, and glossary terms for humanoids and embodied AI.

Browse a curated catalog of datasets for humanoid robots and embodied AI, spanning real-world demonstrations, teleoperation, motion capture, egocentric vision, simulation, manipulation, locomotion, and cross-embodiment robot learning.

90 Datasets · Page 8 of 8

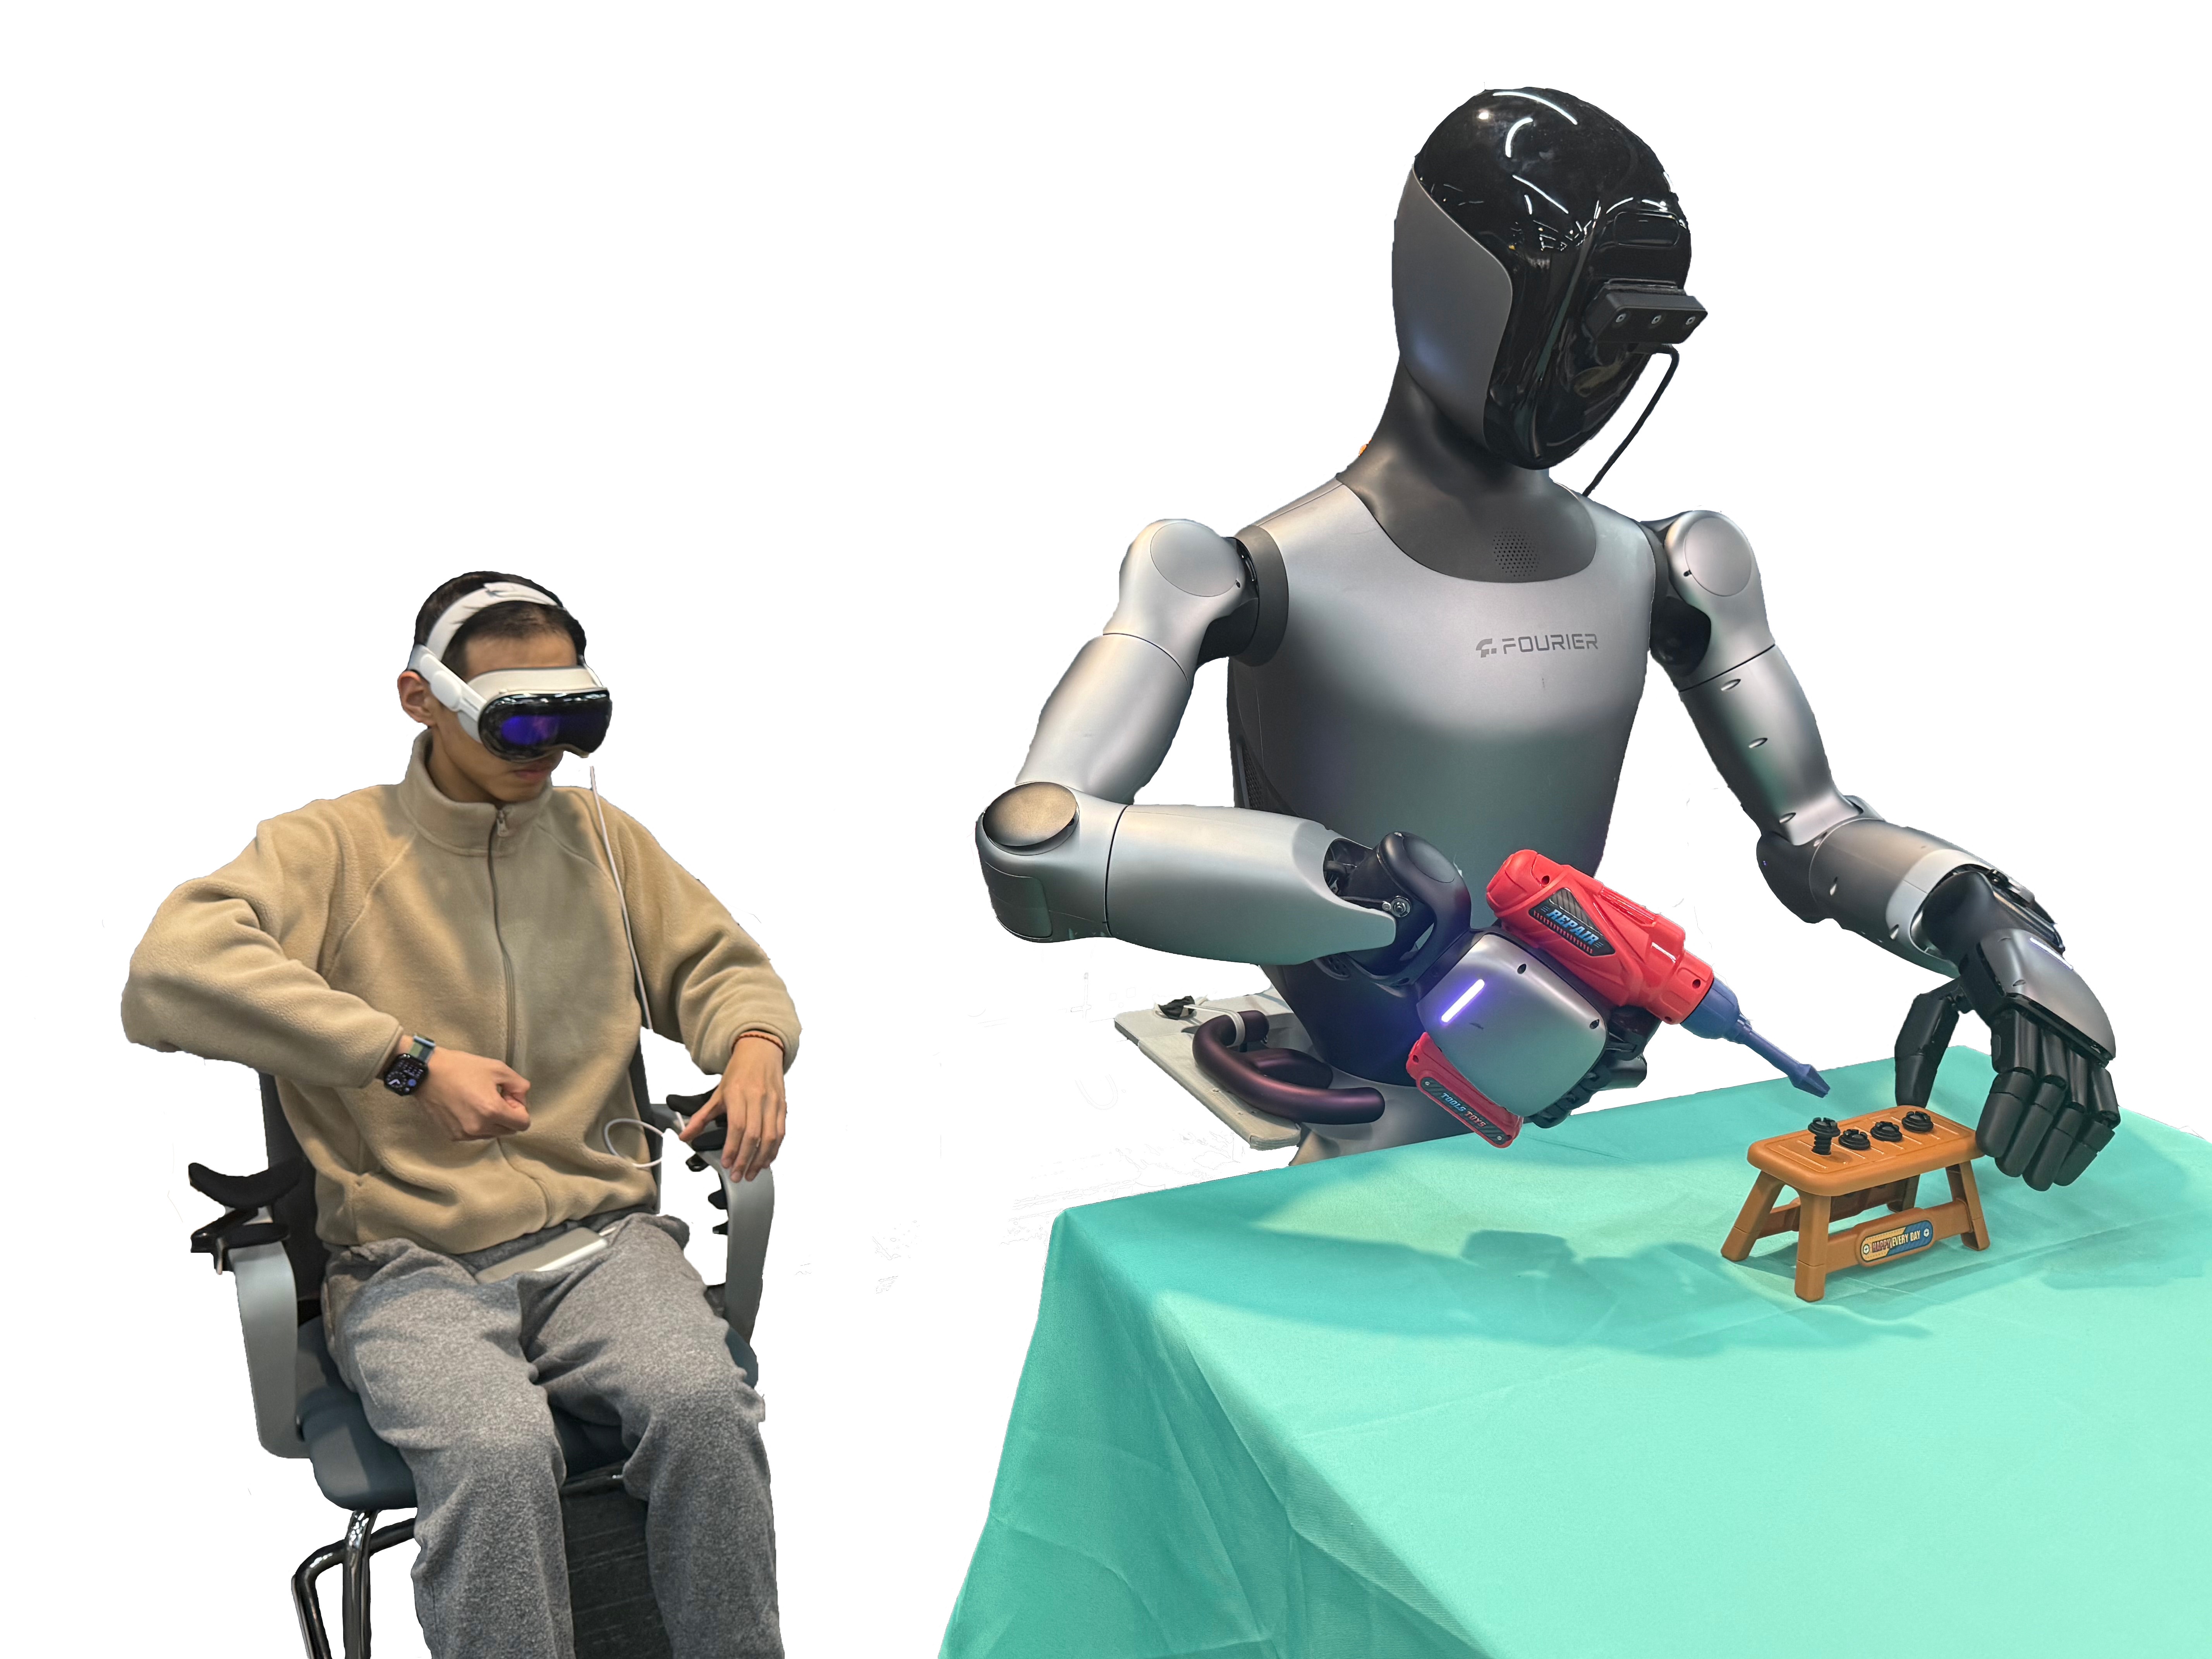
Vision Pro operator teleoperating a Fourier humanoid using a power tool

Fourier ActionNet

Fourier ActionNet contains more than 30K VR-teleoperated trajectories, or roughly 140 hours, from GR1-T1, GR1-T2, and GR2 humanoids using 6-DoF or 12-DoF dexterous hands. It emphasizes bimanual tabletop pick-and-place, pouring, insertion, cabinet interaction, and precise placement with varied household, office, food, and tool objects. RGB-D video, full robot and hand states and actions, end-link poses, and manually verified VLM-generated prompts support imitation learning, VLA, and world-model training.

View dataset →
Unitree G1 performing bimanual cup-and-can manipulation beside an operator

OpenHLM-data

OpenHLM-data is a 298 GB, approximately 1.81-million-row collection of Unitree G1 demonstrations packaged as five corresponding LeRobot datasets. It combines joint-based whole-body teleoperation, stationary manipulation, and robot-free HuMI demonstrations for 12 language-conditioned tasks and fruit-arrangement experiments, including walking, squatting under shelves, pedal use, cart pushing, pouring, and cross-height placement. Stereo head and wrist RGB, 32-D body state, gripper state, actions, and instructions train whole-body-native vision-language-action policies.

View dataset →
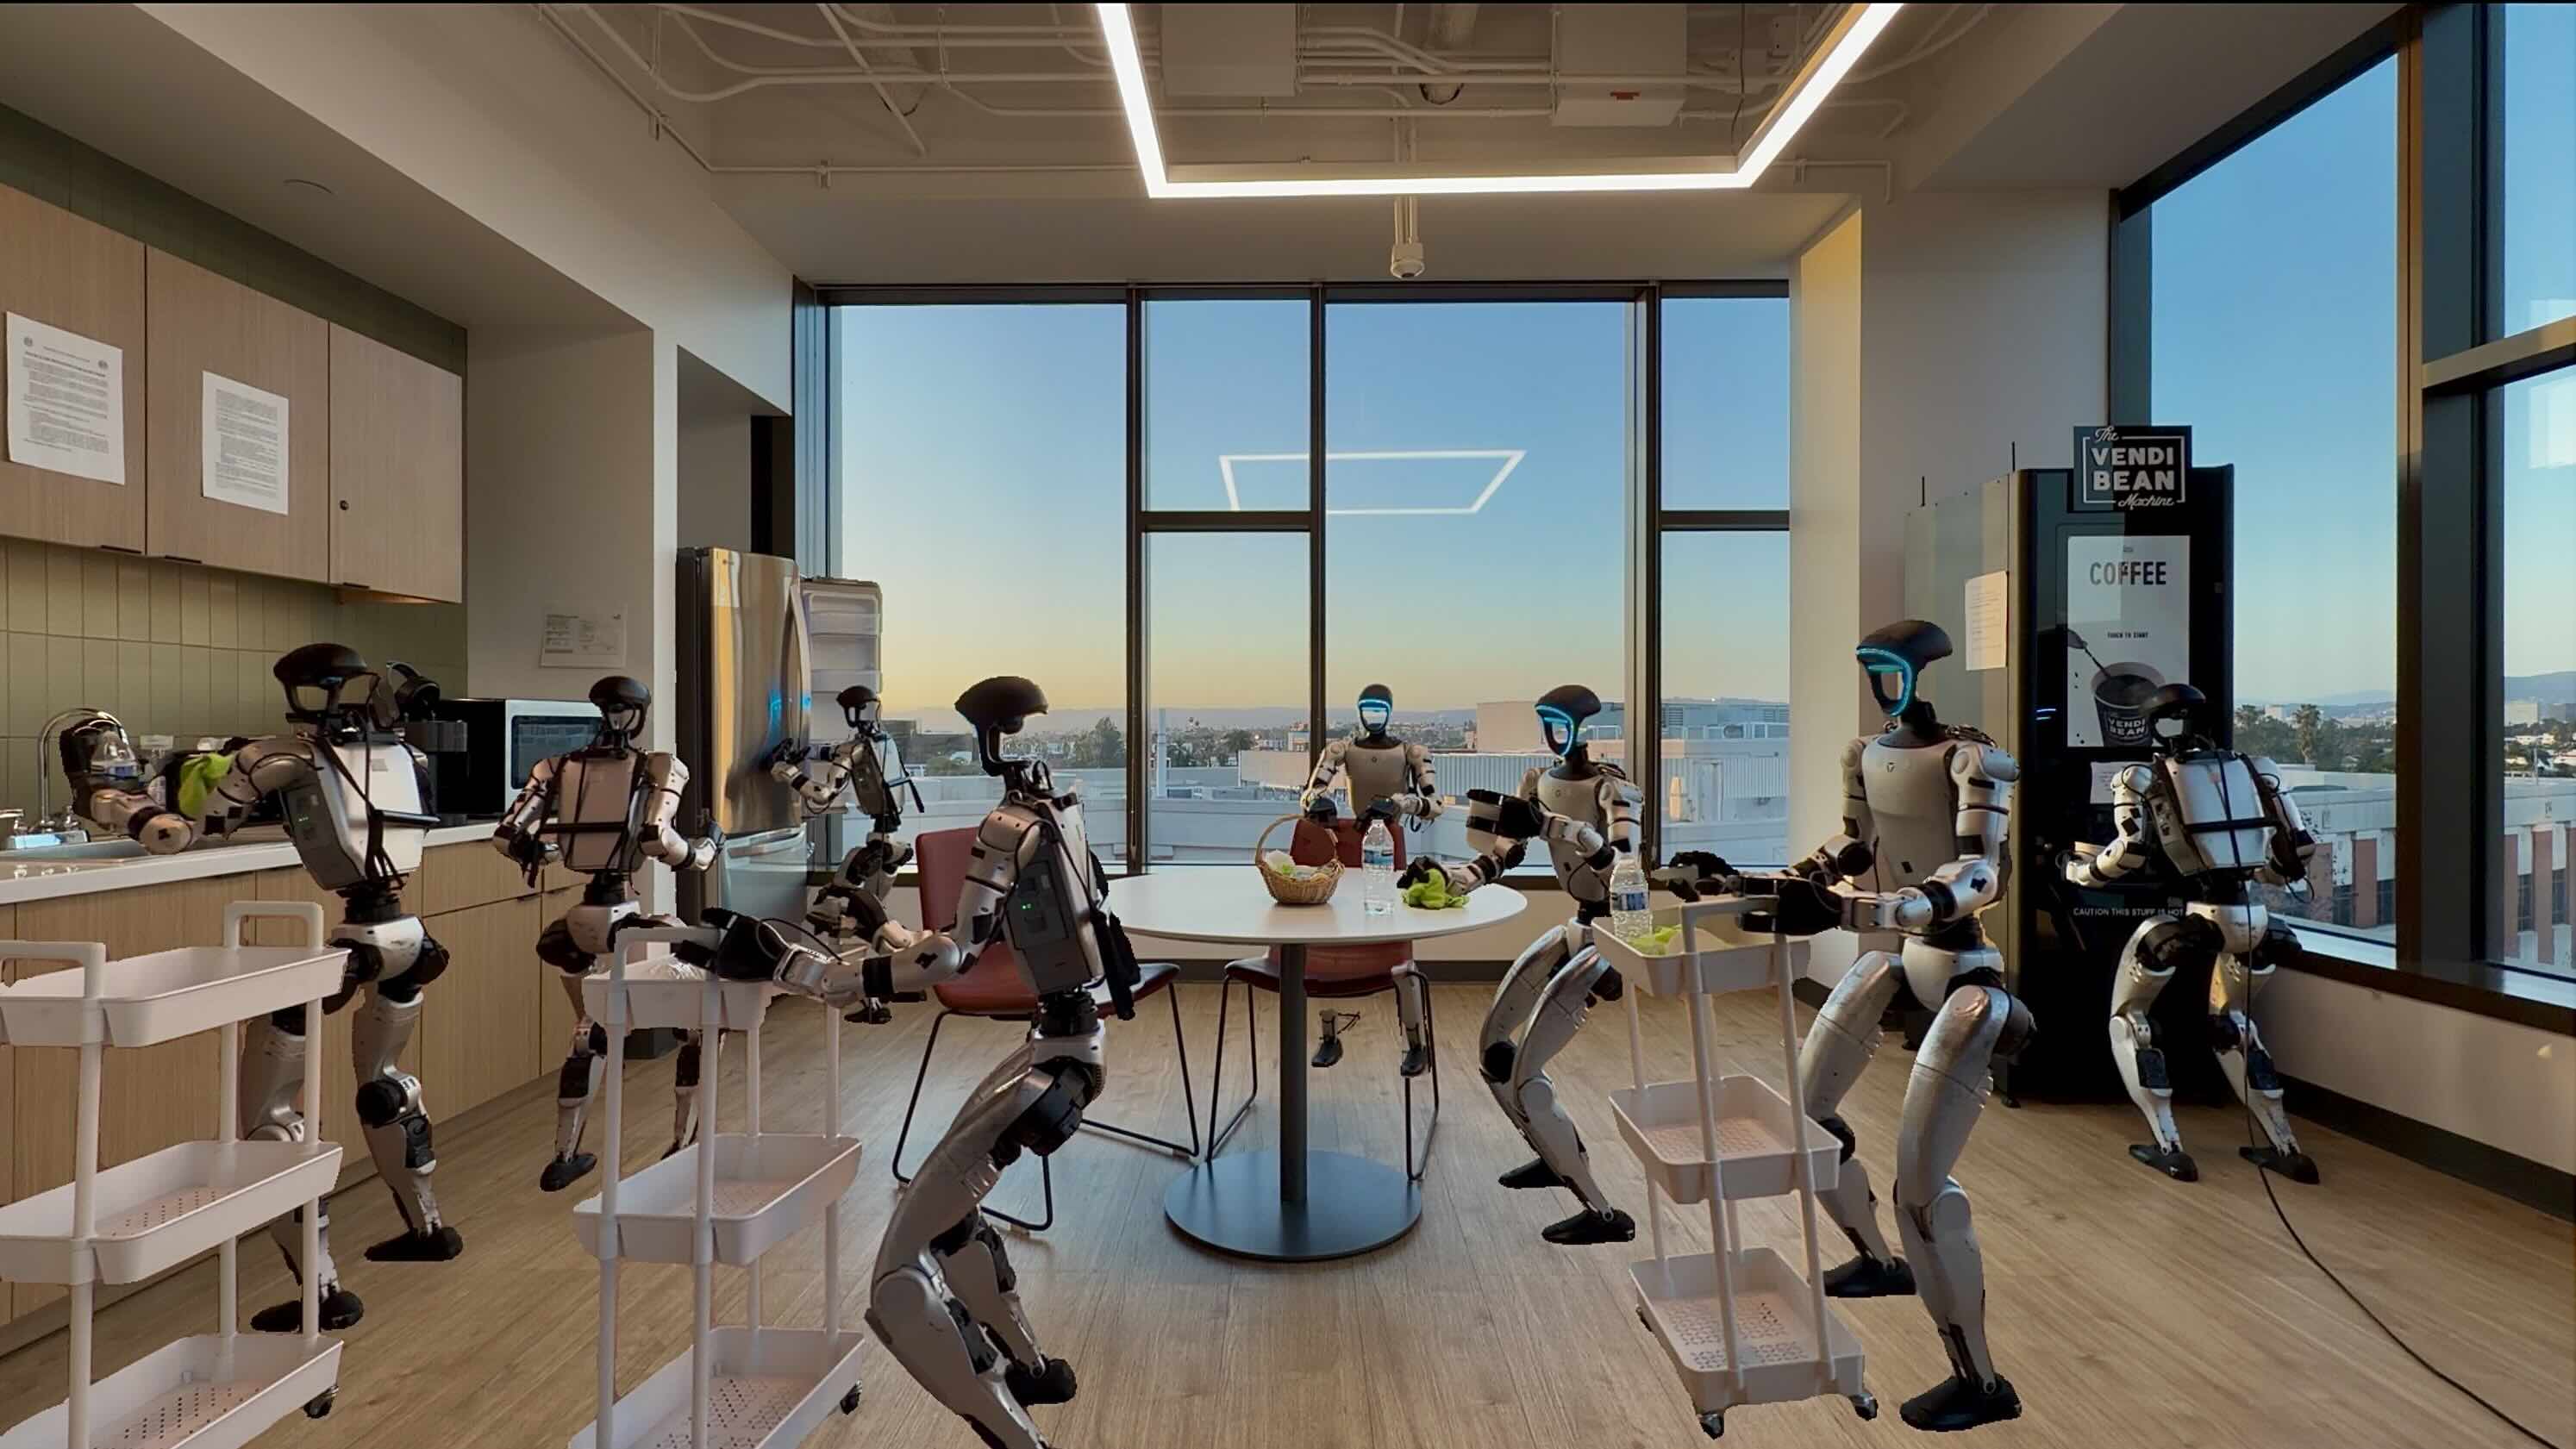
Multiple Unitree humanoids performing kitchen and cart-handling tasks

Ψ₀ / psi-data

The 422 GB psi-data repository combines nine released real-world Unitree G1 task archives with SIMPLE simulation and evaluation packages and supporting Humanoid Everyday and retargeting assets. Robot-specific demonstrations use Dex3-1 hands and cover long-horizon activities such as cart pushing, pouring, cleaning, faucet operation, squatting, carrying, and handing objects to people. RGB observations, robot state, whole-body actions, and teleoperation metadata support Ψ₀ fine-tuning and simulation-based evaluation of dexterous loco-manipulation.

View dataset →
Unitree G1 humanoid picking up a colored block

Unitree UnifoLM-WBT

UnifoLM-WBT is Unitree’s rolling collection of task-specific, real-world whole-body teleoperation datasets for the G1 humanoid, comprising 14 releases in the referenced official collection. Tasks include loading plates into a dishwasher, putting clothing into baskets or washing machines, making a bed, and transporting objects while walking. The LeRobot datasets provide root and 29-joint configurations, end-effector and hand states, desired whole-body actions, and task video, targeting whole-body household policy training.

View dataset →
Humanoid robot performing a tabletop tool-use task

Humanoid Everyday

Humanoid Everyday provides 10.3K Unitree G1 and H1 trajectories, exceeding three million frames across 260 tasks. Human-supervised teleoperation records full-body locomotion, dexterous manipulation, tool use, deformables, articulated objects, precision tasks, and human–humanoid interaction in indoor and outdoor environments. Its 30 Hz observations include RGB, depth, LiDAR, tactile feedback, IMU, joint poses and actions, and natural-language descriptions, supporting general-purpose humanoid policy learning and standardized cloud evaluation.

View dataset →
Unitree G1 humanoid manipulating household items on a kitchen table

HIW-500: Humanoids In-the-Wild

HIW-500 contains 500+ hours and 23,743 episodes of human whole-body teleoperation on Unitree G1 robots across 12 real homes in Southeast Asia. Its 11 long-horizon household tasks include room cleanup, table setting, refrigerator restocking, sweeping, and laundry. Synchronized head and wrist cameras, 29-DoF joint state, end-effector state, IMU, odometry, actions, language, and 148K+ fine-grained subtask annotations support imitation learning and general-purpose household mobile manipulation.

View dataset →