
Bimanual Manipulation Explained: Why Two Arms Are Harder Than One
I use ALOHA's cup-opening task to explain why bimanual manipulation demands coordinated motion, timing, force, training data, and feedback.
10 min readRead article →
Explore practical guides and perspectives on humanoid robot training data and embodied AI, including collection methods, simulation, evaluation, licensing, hardware, and the datasets shaping modern robot learning.
34 Articles · Page 2 of 3
I use ALOHA's cup-opening task to explain why bimanual manipulation demands coordinated motion, timing, force, training data, and feedback.

A VLA can tell a robot what to do. One shoelace attempt shows why prediction before action, feedback during it, and learning after failure must work together.
Physical AI training data needs more than video: humanoid robots also need actions, touch, failures, body state, and evidence from the real machine.

An evidence-ranked guide to humanoid robot applications in factories, warehouses, homes, healthcare, services, hazardous work and space.
What is a humanoid robot? Learn how human-like robots work, where they are used, their history, current trends, limitations, and where the field is heading.

A programmer-first guide to LeRobot datasets, classical control, reinforcement and imitation learning, generative policies, async inference, and VLAs.
Embodied AI explained through the feedback loop between perception and action, with a clear view of what today's robots can and cannot do.

A signal-by-signal comparison of head-mounted video, tracked human capture, and robot-mounted first-person data for humanoid robot training.
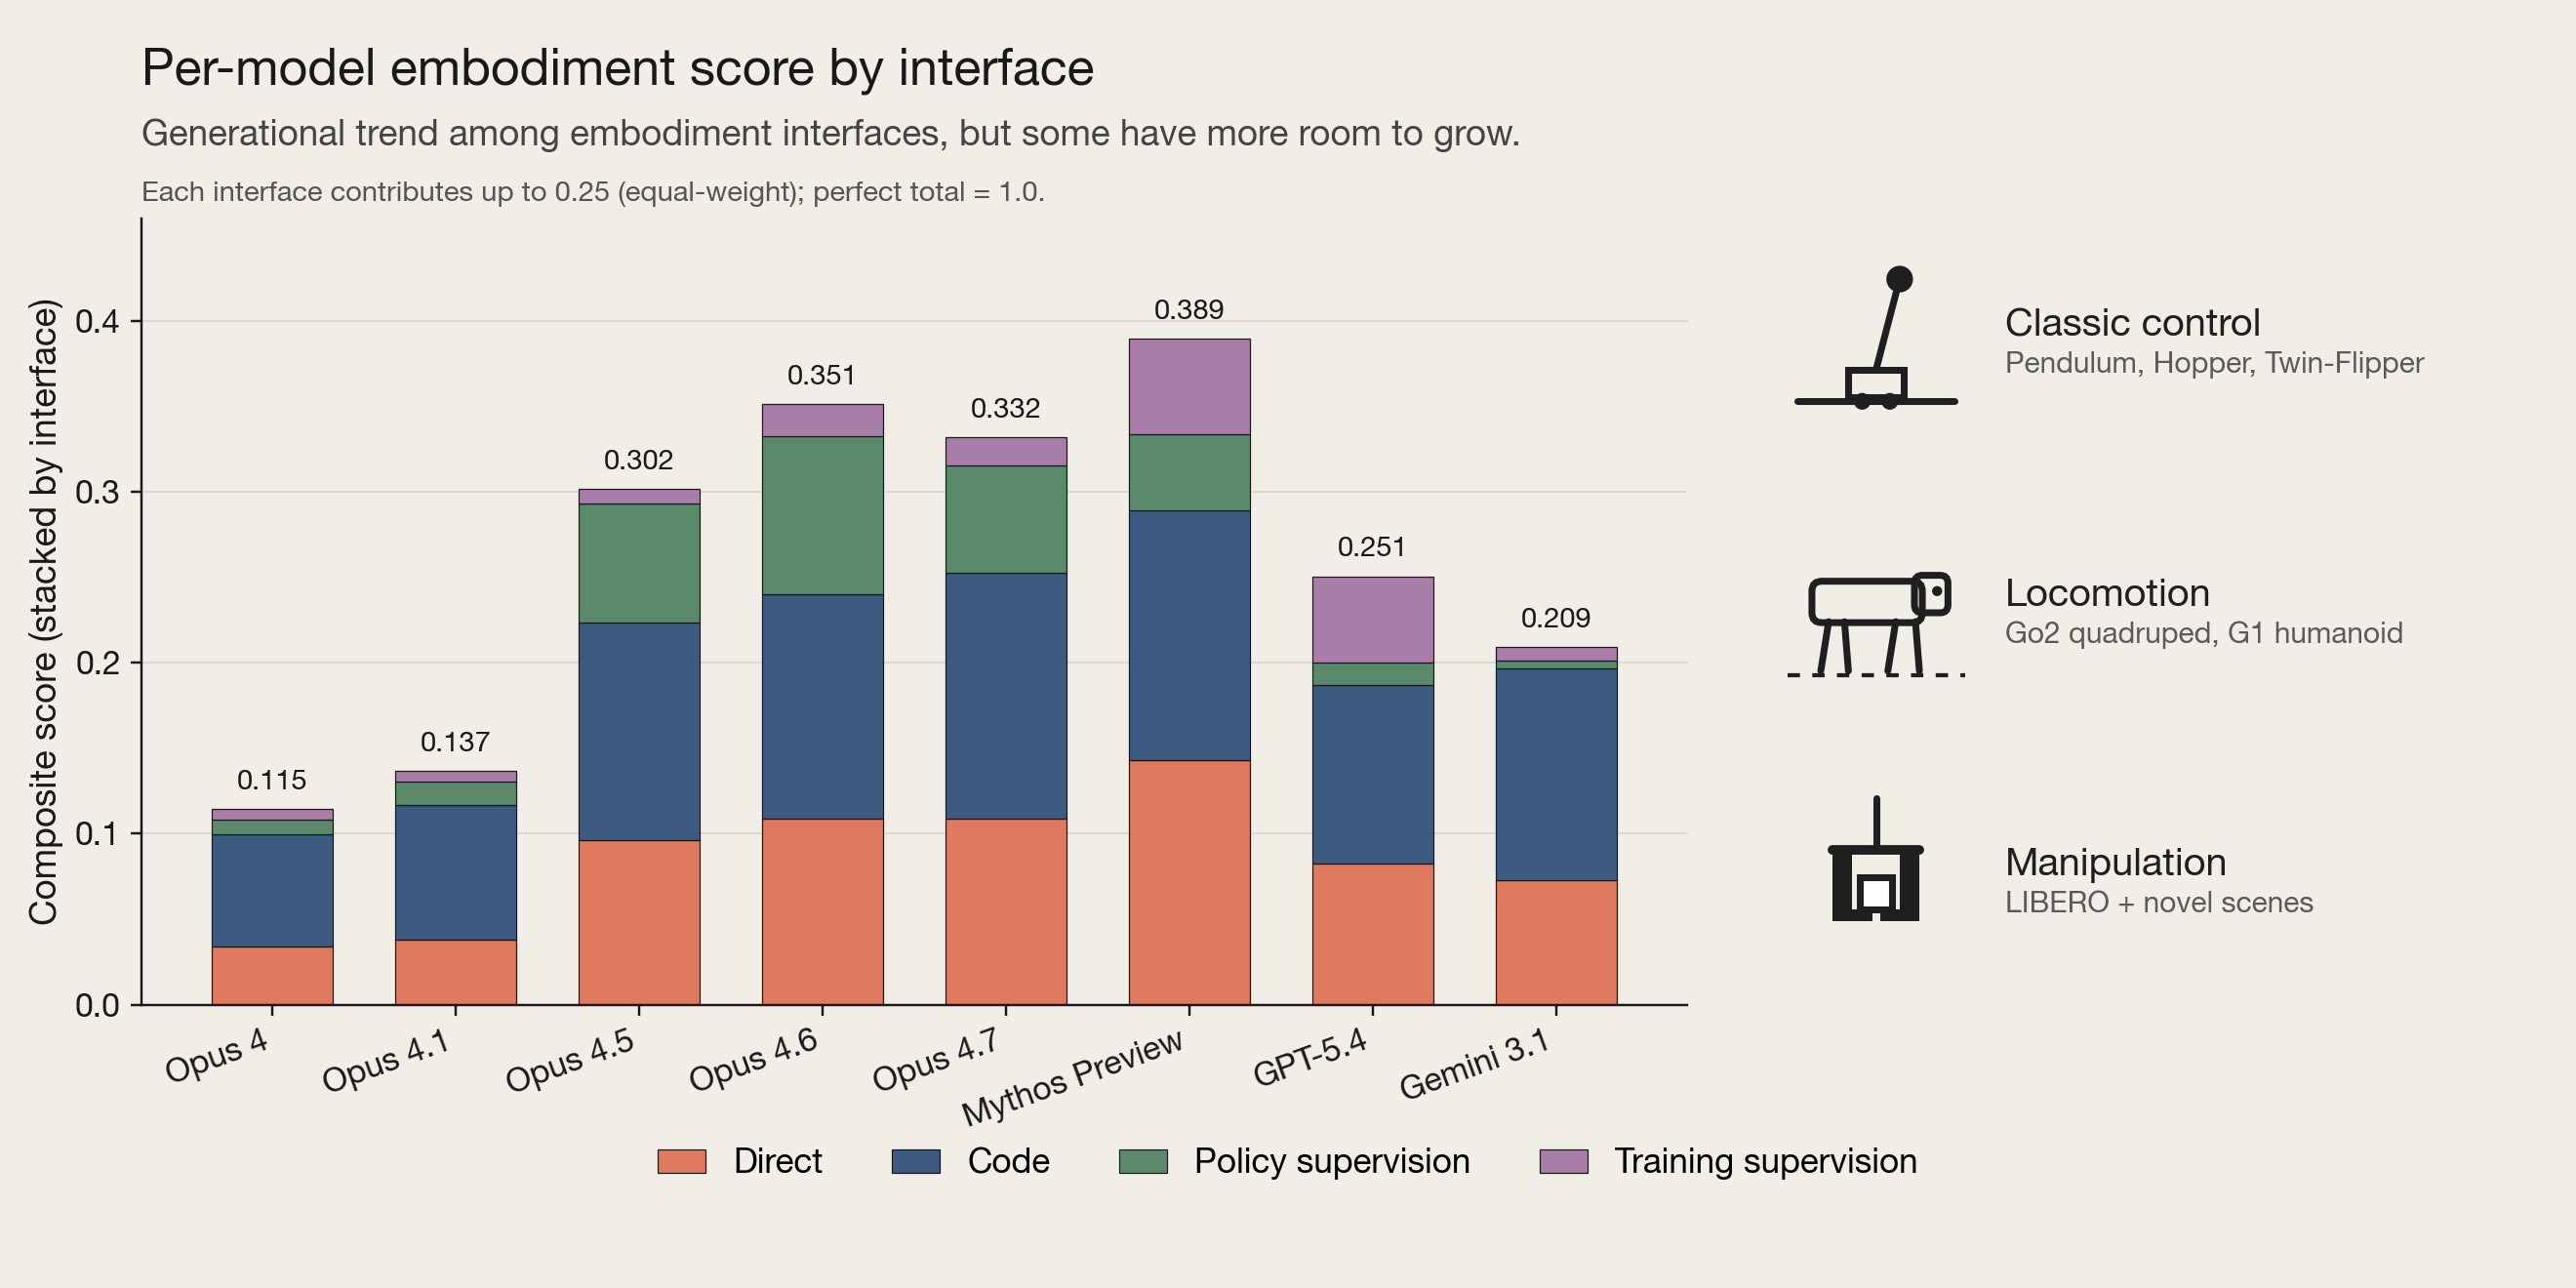
Anthropic's Claude robotics study shows a model becoming physically consequential before it becomes physically reliable.
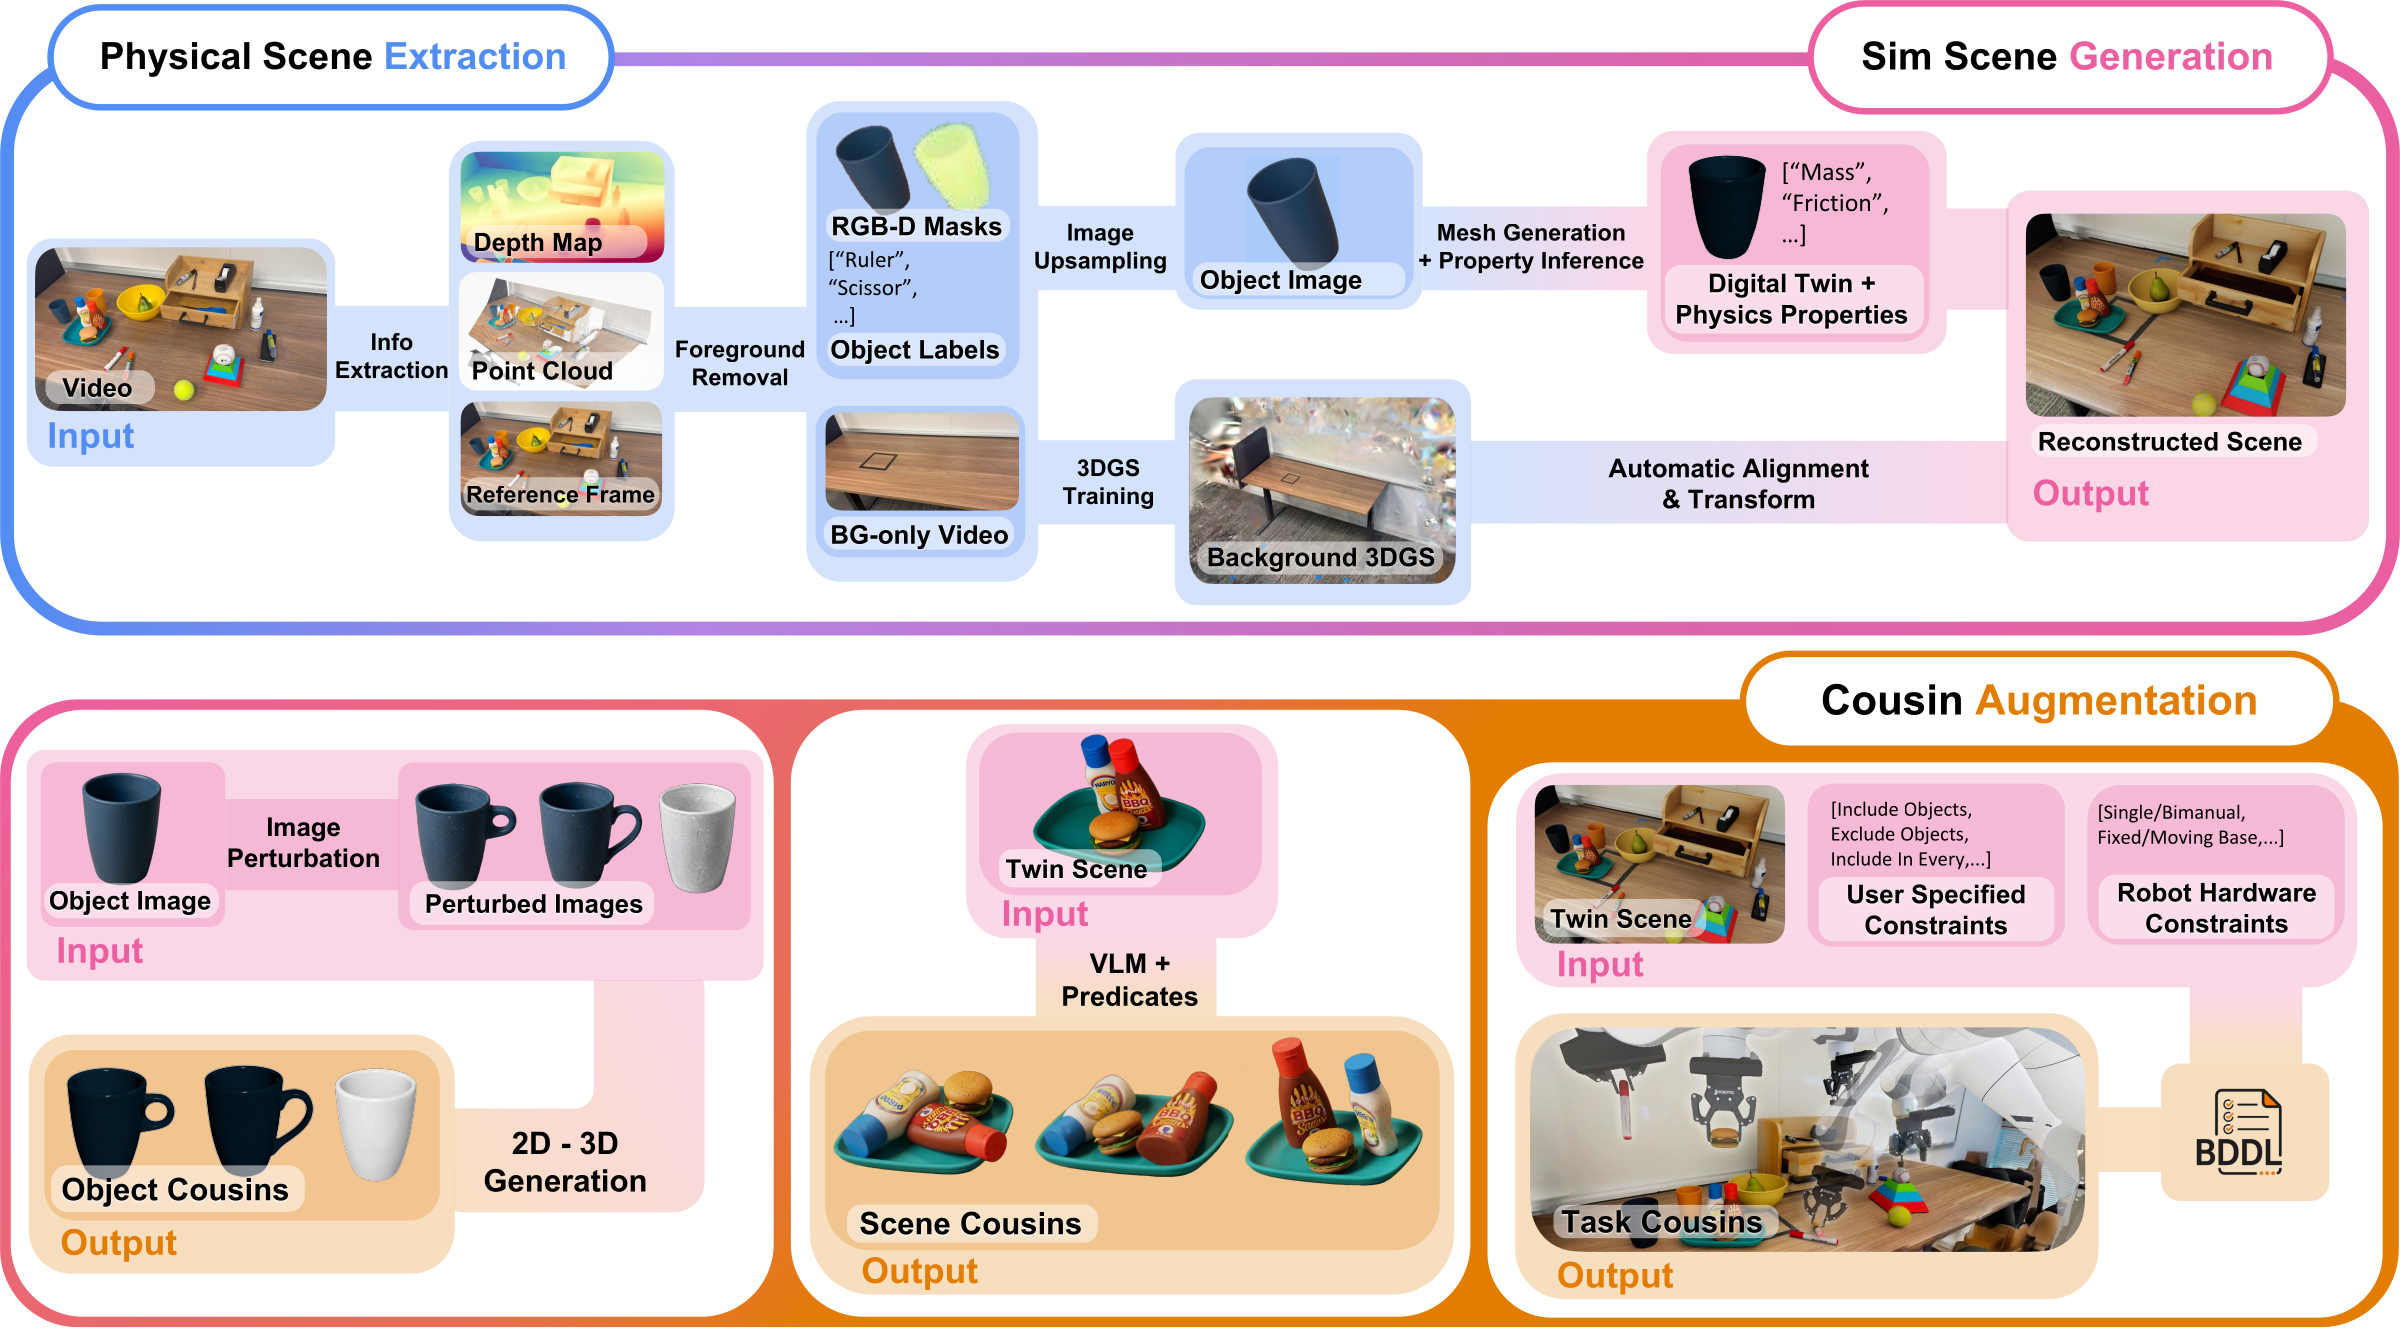
An analysis of NVIDIA Research's SimFoundry, its single-video real-to-sim pipeline, digital cousins, reported sim-to-real results, and the provenance questions behind generated simulation data.

A practical map of humanoid robot, egocentric video, LeRobot, teleoperation, and physical AI data marketplaces, vendors, open datasets, and commercial licensing caveats.
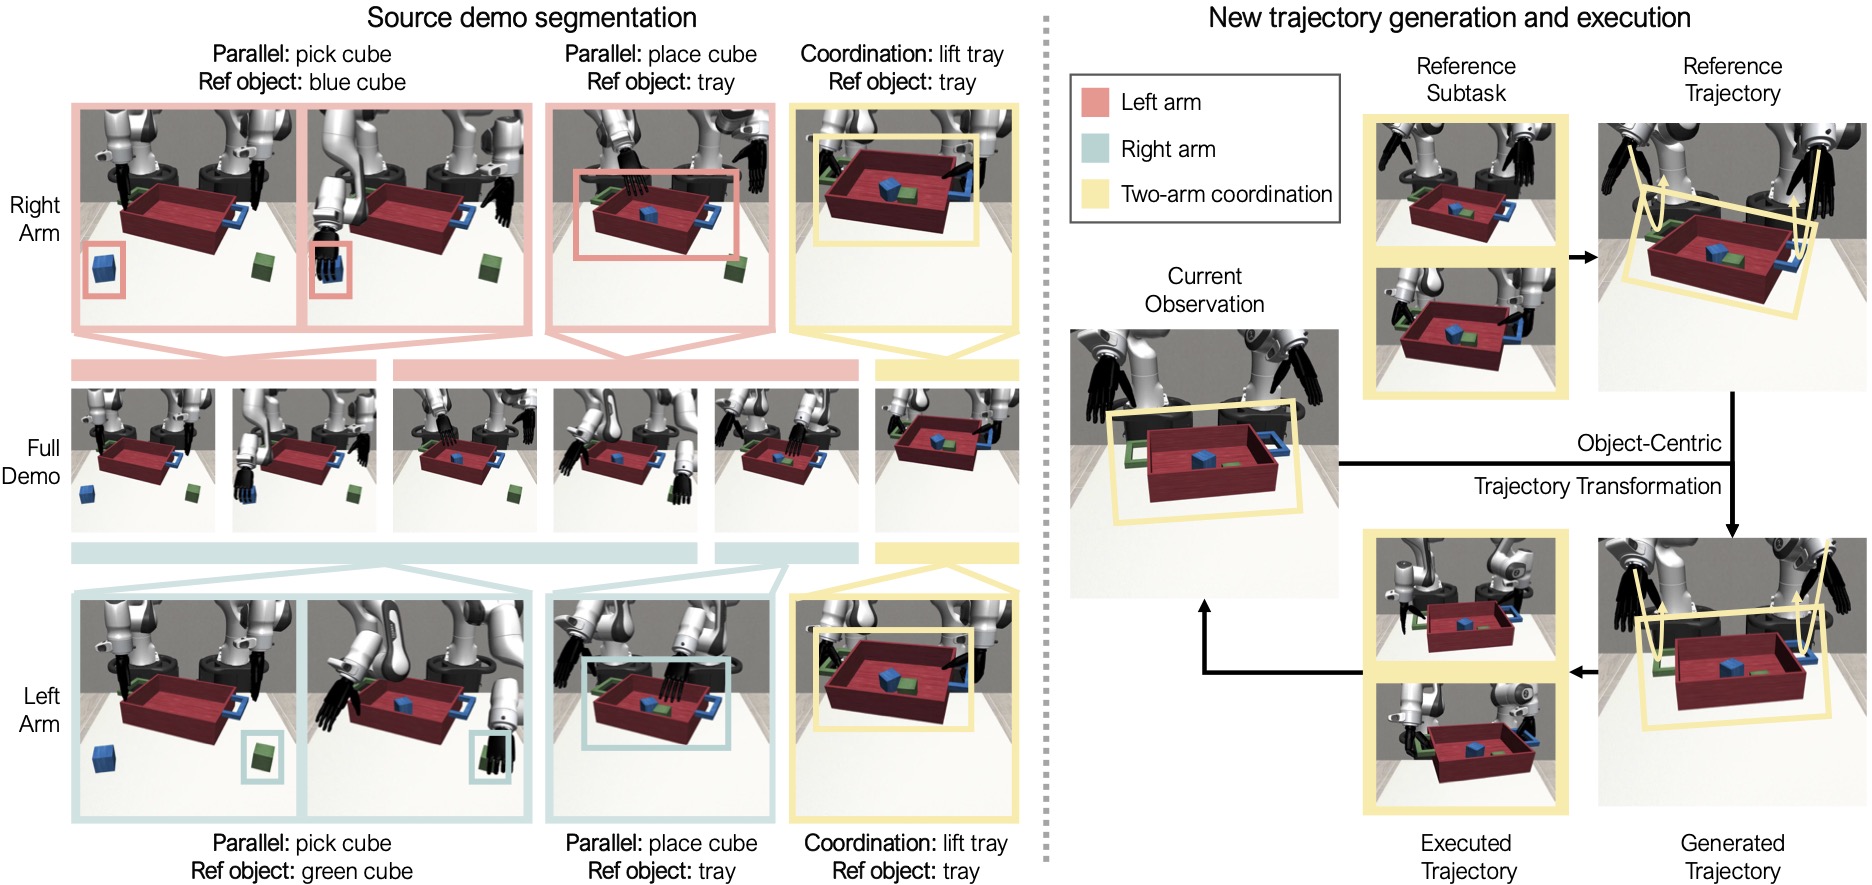
A practical guide to synthetic data generation for robot training, covering domain randomization, synthetic demonstrations, procedural scenes, synthetic labels, generative augmentation, sim-to-real risks, and buyer diligence.